Oculus M3000d Sonar ROS2 Driver
ROS2 (Jazzy) driver for the Blueprint Subsea Oculus M3000d dual-frequency multibeam sonar. This driver should work with any sonar of the M series.
A C++ (without ROS) sonar interface is under development in the
cpp branch of this repo.
The purpose of this driver is to retrieve raw sonar data with custom code during sensor deployment, either in a ROS2 perception-control stack, or in a custom C++ architecture for the robotic system. It is not a substitute for the vendor application Oculus ViewPoint V2.
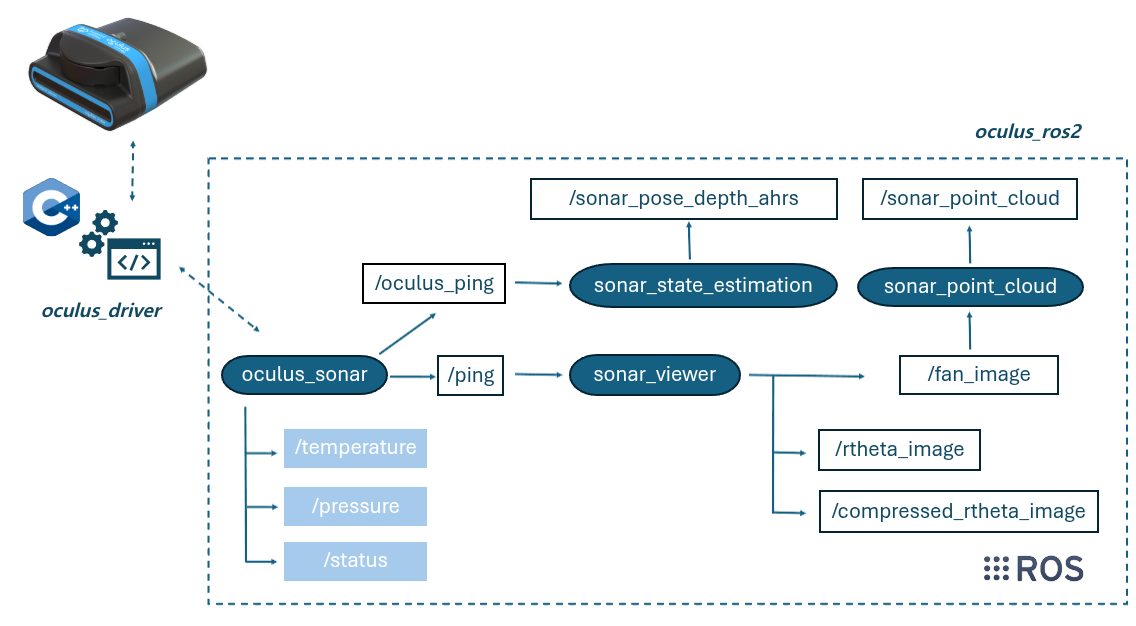
Fig. 1: ROS2 communication architecture. The oculus_sonar node instantiates a driver client to
establish TCP/UDP communication with the hardware. The sonar_viewer node converts the received echo
to a cartesian (fan) image and a polar image, while the sonar_point_cloud node publishes the planar
point cloud by thresholding high-intensity echoes. sonar_state_estimation is a prototype that uses the
sensor AHRS and pressure sensor to estimate the sensor pose, but it is currently not reliable.
Software “Development”: Updating Existing Drivers
This package is adapted and extended from the M1200d ROS2 driver by ENSTA Bretagne Robotics, and the underlying low-level driver Sonar Interface.
The M1200d software has been updated for the M3000d using the up-to-date Blueprint Subsea proprietary oculus_sdk (kindly shared by the technical support team).
Some useful PDF documents to develop the sonar software, use the sensor and interpret the data are collected in the assets folder of the repository.
Requirements
This ROS2 metapackage (with the low-level sonar driver) was developed, tested, and built using:
Ubuntu 24.04 LTS
ROS2 Jazzy
CMake 3.28.3
A Dockerfile with instructions to build the image and run it from any machine is planned. (The current docker setup has not been tested.)
Repository Structure
This repository contains all the code necessary to build and use the Blueprint Subsea Oculus M3000d sonar driver. It also includes the original proprietary SDK (the one used in the official Blueprint ViewPoint V2) as reference code. Note that the SDK code is not used during the build process.
oculus-m3000d-ros2-cpp-driver/
├── docker/                  # Docker configuration files (work in progress...)
├── assets/                  # Documentation images and files
├── oculus_driver_lib/       # C++ driver library
├── oculus_ros2/             # ROS2 packages
│   ├── oculus_interfaces/   # Messages / services
│   ├── oculus_ros2/         # Main driver package
│   └── Data/                # Optional data directory
├── reference_oculus_sdk/    # Reference SDK code
├── LICENSE
└── README.md